WorldRobotHub
Start with one complete cleaning circuit. Include access to the water point, the recovery drain, the charger and every door the machine will cross. Mark where people queue, where furniture can move and where the floor changes texture.
Measure three clearances
Record the narrowest straight passage, the narrowest turn and the room available at the end of each run. The Mira and Marvel manufacturer sheets distinguish machine width from minimum passage width. The Mira lists a 550 mm body and a 660 mm minimum passage. The Marvel lists a 699 mm body and an 850 mm minimum passage. Use the supplier’s operating clearance as the starting point for the site trial.
Match the cleaning head to the task
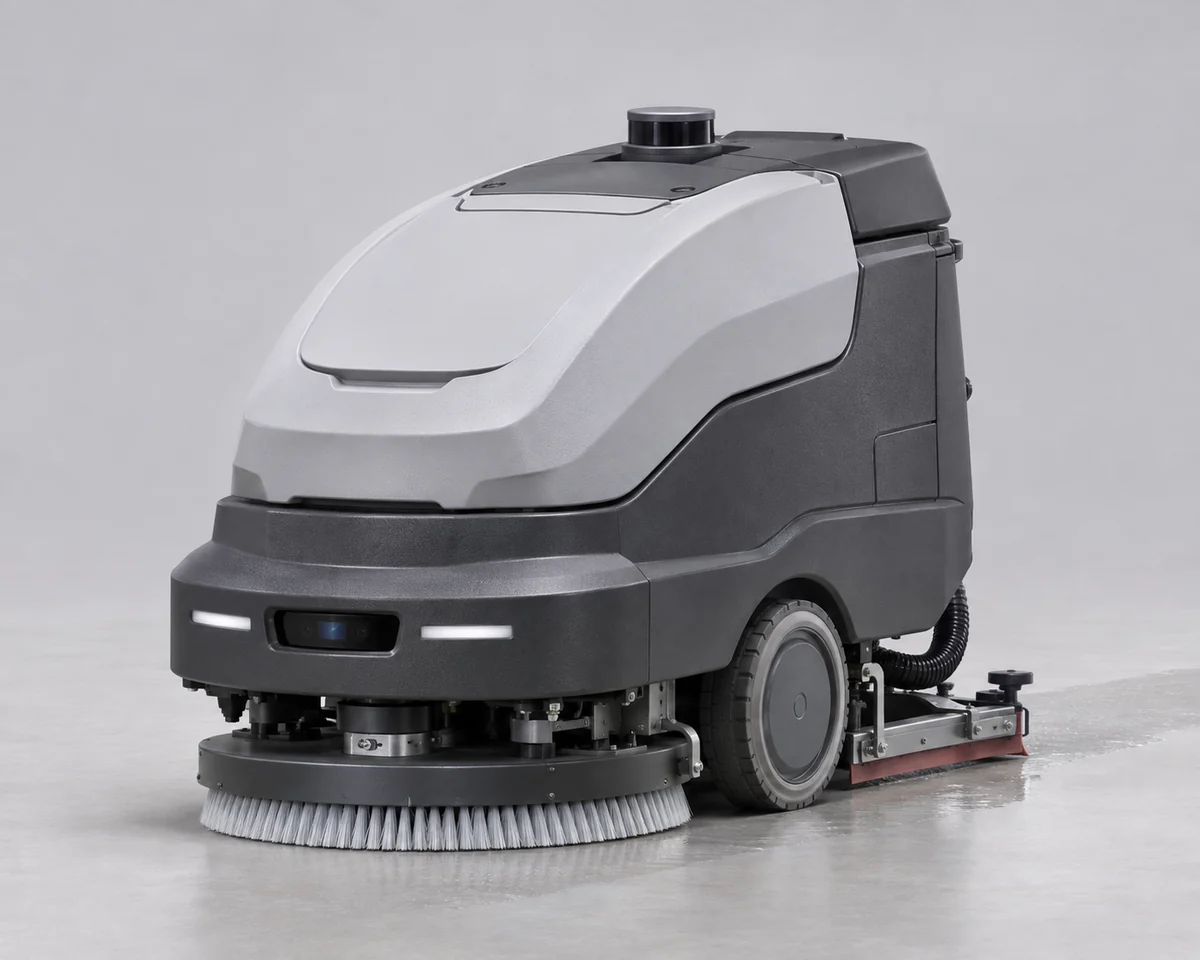
Compare like modes. Scrubbing a hard floor, sweeping debris and dust mopping are separate jobs with separate widths and run times. For the Omnie, record the brush configuration on the quotation because the disc and roller change both the cleaning width and the machine weight.
Time the whole circuit
Ask the supplier to run the route twice. Record active cleaning time, water and recovery stops, and any staff intervention. Calculate usable area from the portion the machine actually completes. Add manual touch-up and charging to the shift plan.